Huan-ang Gao (高焕昂)

Ph.D. Candidate, Tsinghua University

Co-founder & CTO, Einsia.AI

Mail: cc7w [at] foxmail [dot] com

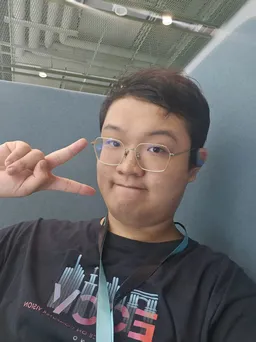
Photo of Huan-ang Gao

I'm currently serving as CTO of Einsia.AI, where our mission is to systematically study the capability boundaries of AI on real-world tasks — and to push those boundaries forward. We believe that within the next five years, AI agents will become core participants in all kinds of expertise work.

To get there, I firmly believe in The Bitter Lesson: what matters are general methods that scale with computation, and today that means scaling learning through agentic rollouts and environment feedback. I am broadly interested in bringing LLM agents into every specialized field where real work gets done, as a path toward general-purpose agents, and I think about this along three lines:

  1. Data & Evaluation. An RL environment consists of the instructions given to the agent, a sandbox equipped with the right tools, realistic data for the agent to work on, and a verifier that reliably judges the outcome. Two things matter here: how to turn expert workflows into the right instructions and sandboxes, and whether the verifier measures the resulting signal correctly and informatively.
  2. Scalable Rollouts. The context window of a model is finite. We cannot fit every past experience and lesson into it, so simply scaling compute will never absorb everything that long-horizon work demands. Sustained progress therefore rests on two layers. The first is the external harness — tools and scaffolding that reliably organize history (what to retrieve, compress, or discard, and what state to surface at each step), so experience can accumulate outside the model. The second is internalization — post-training and continual training, such as mid-training on verified trajectories, that distills experience the model has already validated into its own weights, instead of merely imitating a trace.
  3. Scalable Learning. Learning is ultimately a problem of credit assignment: given a long trajectory and a sparse, delayed reward, which decisions deserve the credit? A good learning algorithm is one that answers this efficiently.

If you're interested in related topics and would like to collaborate, feel free to reach out!

Education

  • Tsinghua University logo
    Ph.D. Candidate in Computer Science 2024 - Present
    Tsinghua University

    Advisor: Prof. Ya-Qin Zhang, Founding Dean of Institute for AI Industry Research (AIR), Tsinghua University.

  • Tsinghua University logo
    B.Eng. in Computer Science 2020 - 2024
    Tsinghua University

    GPA 3.98 / 4.00, ranked #1 out of 204 in the Department of Computer Science and Technology.

    Received the highest distinction for undergraduates at Tsinghua in 2023 and the SenseTime Scholarship in 2024.

Past Research

† first or co-first author
  • Agentic Reinforcement Learning

    I had a wonderful year-long research journey as an intern at ByteDance Seed, where I was a core contributor to the coding agent team for Seed 1.8 and Seed 2.0.

    During this time, I worked on both infrastructure and algorithms. On the infrastructure side, I contributed to building the RL training infrastructure and the data infrastructure behind it. On the algorithm side, I designed difficulty-aware data scheduling: when the data pool exceeds the training budget, the sampling ratio of each problem is adjusted dynamically according to its difficulty, together with mechanisms such as a replay buffer to reuse informative samples.

    • † Open-MOPD: Diagnosing and Fixing Capability Imbalance in Multi-Teacher On-Policy Distillation, arXiv 2026
    • † Weak-to-Strong Generalization via Direct On-Policy Distillation, arXiv 2026
    • CUDA Agent: Large-Scale Agentic RL for High-Performance CUDA Kernel Generation, arXiv 2026
  • Generative Simulation (Now termed as) World Models for Embodied AI

    The development and iteration of autonomous driving and robotics policies are limited by the high costs, low efficiency, and safety risks of real-world testing. Generative AI offers a potential breakthrough by enabling high-fidelity, interactive, and editable simulation testing.

    I worked on building world models that drive simulation with generative methods, along two directions: high-fidelity scene reconstruction, building digital twins of real scenes with NeRF or Gaussian splatting; and controllable content generation, leveraging the generative priors of diffusion models to provide endless, controllable scene variations and edge cases on top of reconstructed scenes.

    • † PartRM: Modeling Part-Level Dynamics with Large Cross-State Reconstruction Model, CVPR 2025
    • † Ctrl-U: Robust Conditional Image Generation via Uncertainty-aware Reward Modeling, ICLR 2025
    • † SCP-Diff: Spatial-Categorical Joint Prior for Diffusion Based Semantic Image Synthesis, ECCV 2024
  • Data Efficient Scene Parsing

    2D/3D perception is fundamental to embodied intelligence, but the extremely high cost of data annotation severely restricts the development of perception models.

    My early research focused on data-efficient perception, particularly semi-supervised learning and domain adaptation. In DQS3D, I proposed a single-stage, densely-matched semi-supervised framework for 3D object detection, addressing the insufficient training signals caused by sparse matching in previous methods. I also explored self-supervised depth estimation, indoor layout estimation, and HD map generation.

    • † DQS3D: Densely-matched Quantization-aware Semi-supervised 3D Detection, ICCV 2023
    • † From Semi-supervised to Omni-supervised Room Layout Estimation Using Point Clouds, ICRA 2023
    • † Training-Free Model Merging for Multi-target Domain Adaptation, ECCV 2024

Services

  • Building a community for embodied AI research and applications.

  • Computer Vision: CVPR, ICCV, ECCV, WACV, 3DV

    Machine Learning & AI: NeurIPS, ICML, ICLR, AAAI

    Robotics: CoRL, ICRA, IROS

    Journal: TPAMI

  • Software Engineering (23Spring - 25Fall)

    Digital Logic Experimentation (24Spring, 25Spring)

    Computer Organization and Design (23Fall)

  • Technical training, competition guidance, and research & internship opportunities for undergraduates.

  • Infrastructure: built the association's homepage and technical documentation.

    Training: organized the summer training camp for freshman year students.

    Resources: launched an internal resource portal gathering internship opportunities and graduate admissions information for students in the department.